Computer VisionAI
Perception
Visual recognition, inspection, tracking, and spatial awareness turn camera and sensor input into context for robotic decisions.
Nuareto platform
Nuareto connects computer vision, robotic planning and control, sensor fusion, simulation, edge intelligence, and fleet operations in one platform.
Platform modules
Configure the modules together for sensing, autonomous decisions, edge execution, and operational oversight.
Visual recognition, inspection, tracking, and spatial awareness turn camera and sensor input into context for robotic decisions.
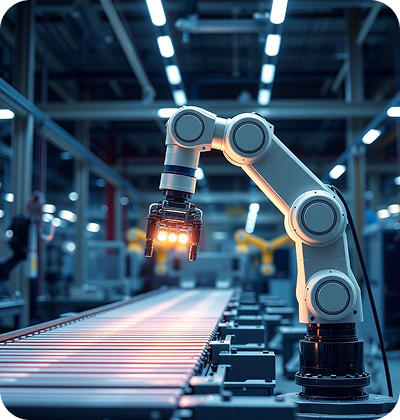
Robotic planning and control logic combine sensor fusion, task execution, and safe fallback behavior.
Low-latency inference, device orchestration, and telemetry bring intelligence close to sensors and actuators.
Simulation, fleet workflows, monitoring, and model updates support operation across devices and environments.
Platform workflow
The platform links environment setup, simulation checks, and monitored edge operation.
Set up sensors, environment context, safety boundaries, and operator roles.
Test perception and autonomy in simulation, then review behavior against sensor data.
Run and monitor at the edge with telemetry, fleet workflows, and model updates.
Pilot access
Explore how Nuareto modules fit your sensors, autonomy needs, and edge deployment.